JARL
About this project
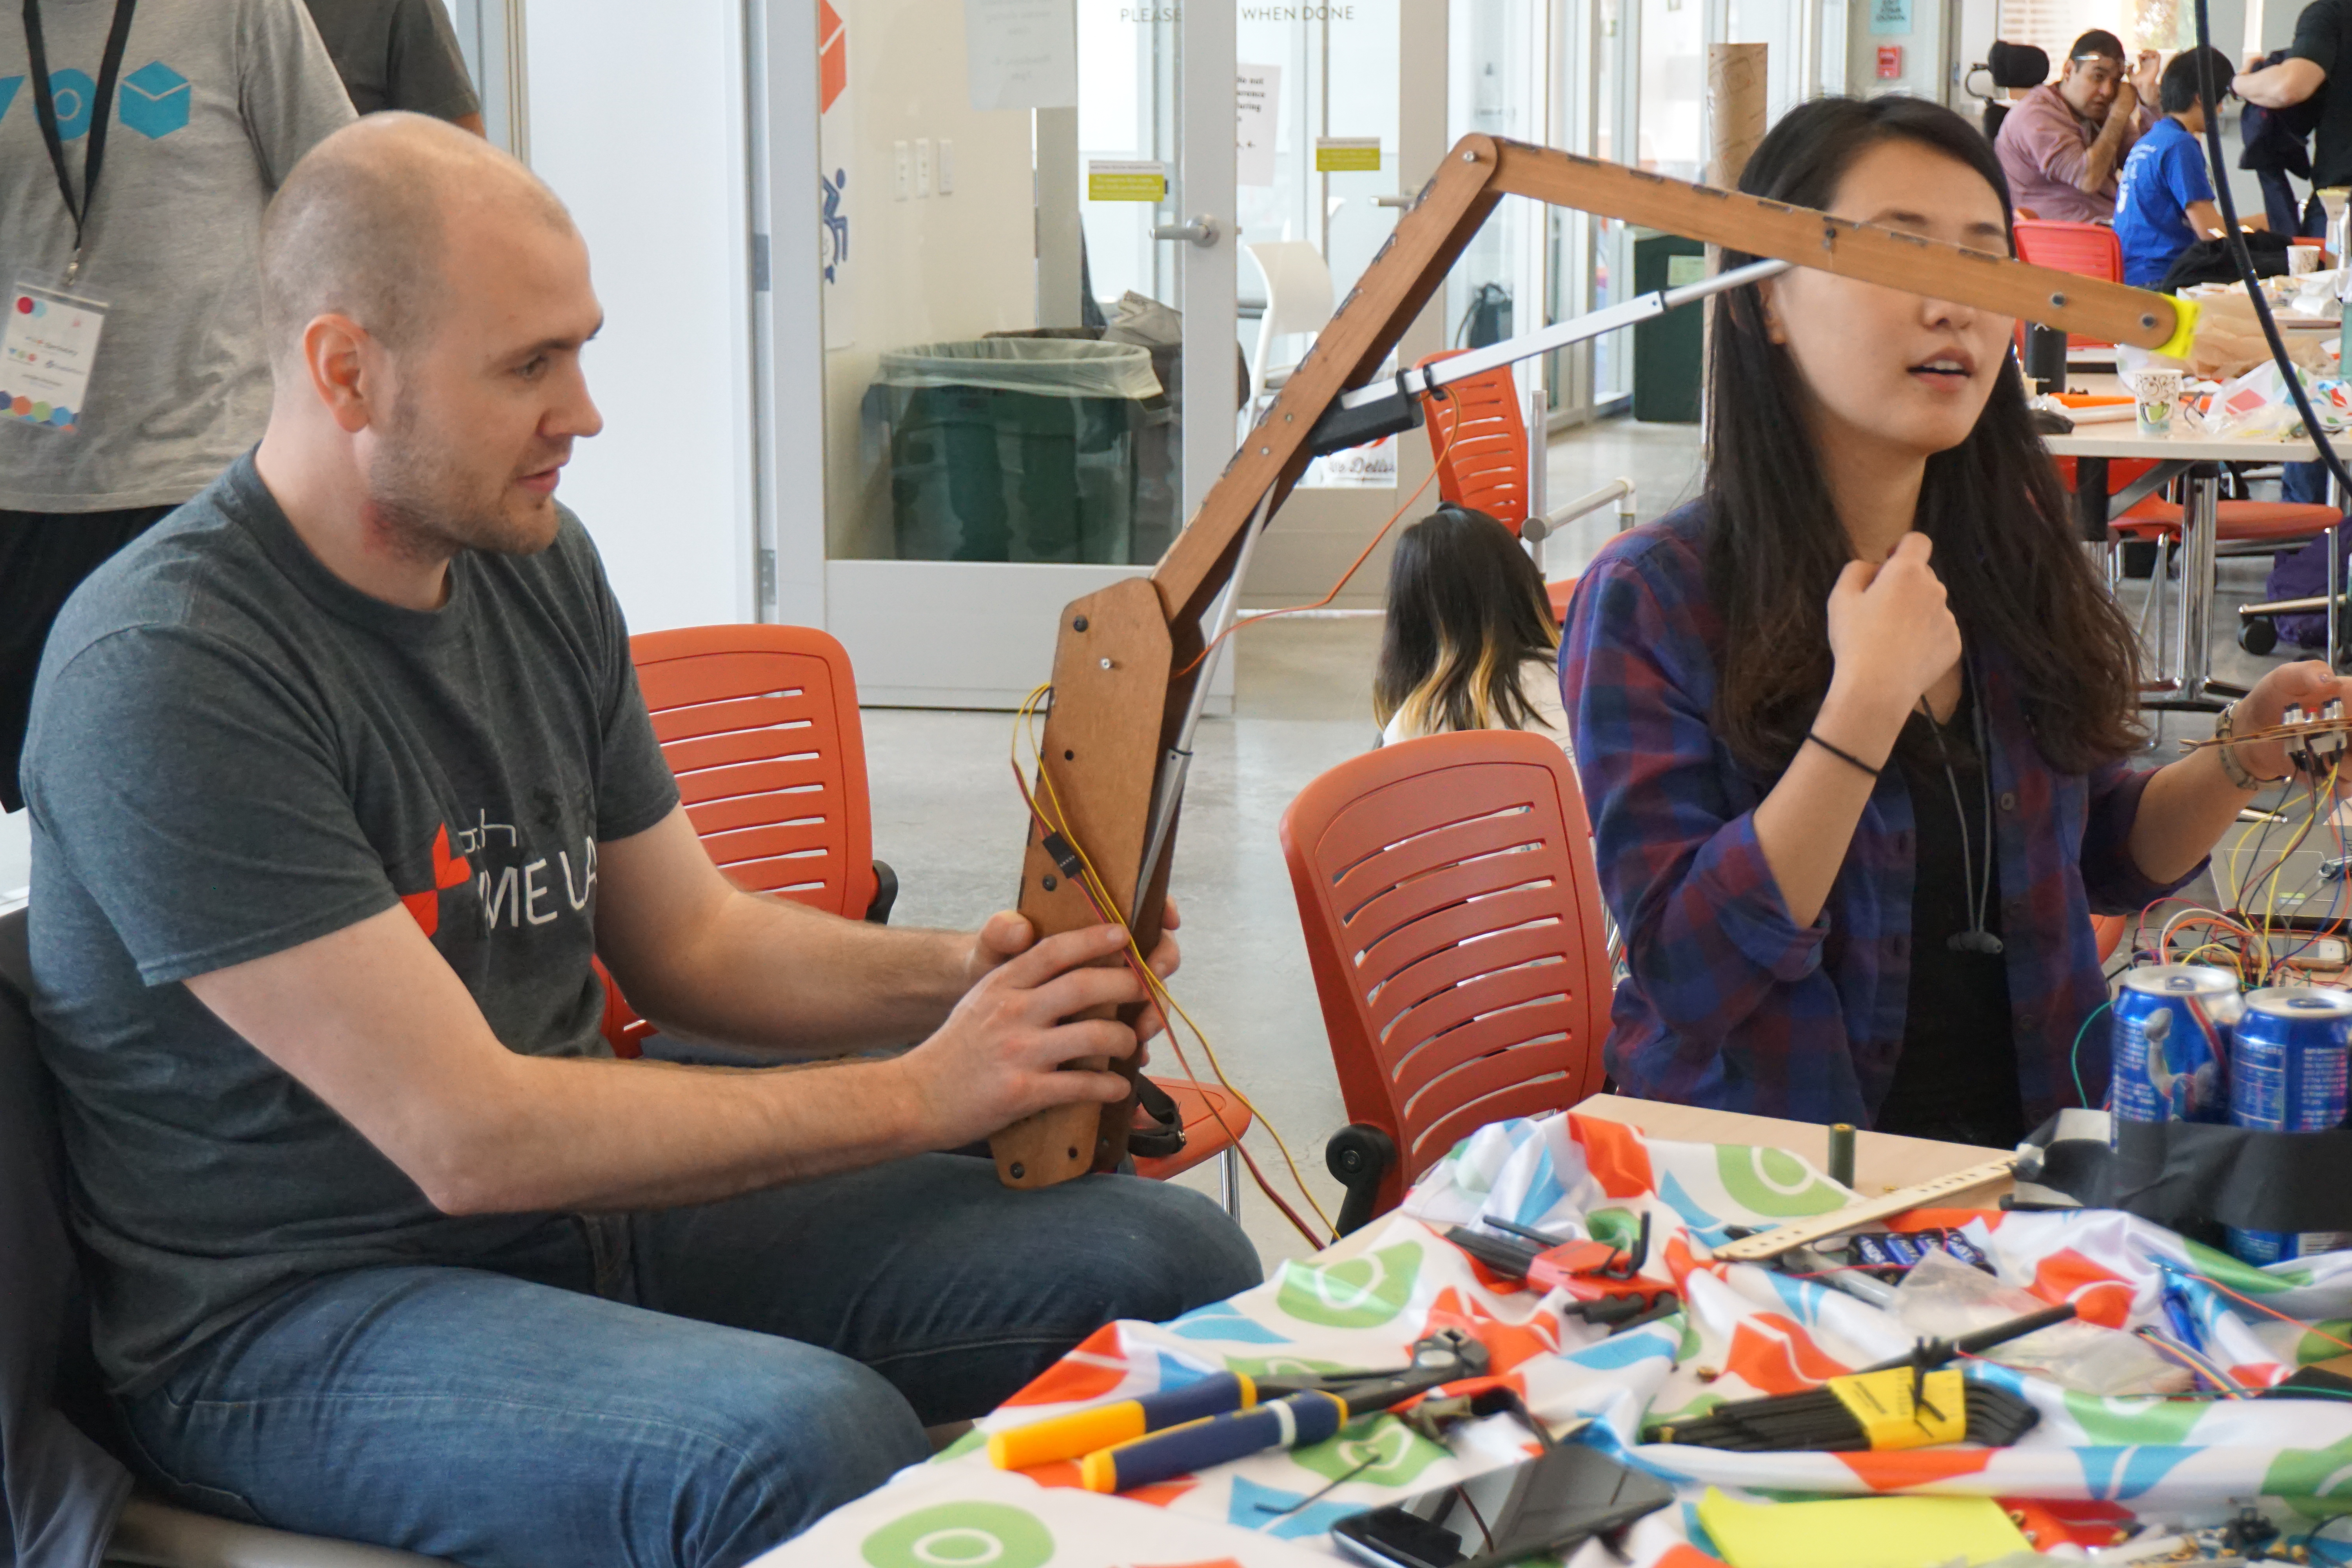
Need-Knower Jade created the first prototype of JARL before the makeathon, together with Owen, the Need-Knower for HouseAUTO, and built off of that knowledge at TOM:Berkeley with the new JARL team. Unlike past prototypes which were non-functional skeletons, this JARL model is equipped with two degrees of freedom and a laser pointer at the end to make operation easier and more accurate. The JARL team’s minimum viable product is a robotic limb that can press elevator buttons, achieved through the two degrees of freedom.
The challenge
For people with limited to no arm and leg function, a robotic arm attached to a wheelchair can function as a backup working limb. Unfortunately, solutions that are currently on the market can cost $50,000, making them unrealistic for many people to purchase. Desktop arms exist and are often cheaper, but are weaker and have a limited range of motion.
Who it helps
The need knower is Jade, she uses a wheelchair.
Project details
- Stage: Working Model
- Built by the Berkeley community, Berkeley, United States of America
- Team: Jade
- Category: Daily Living
- 5 downloads
The build files for JARL are free to download from this page - open source, shared by TOM: Tikkun Olam Makers.
Related projects
- Tendon Glove
- Single-Button Remote
- Hoai
- HouseAUTO
- Yakir's Team
- Independent and Modified Pediatric Feeding Solutions
Browse all TOM projects · Search projects · TOM communities · Makeathons and events