Hybrid Walker
The challenge
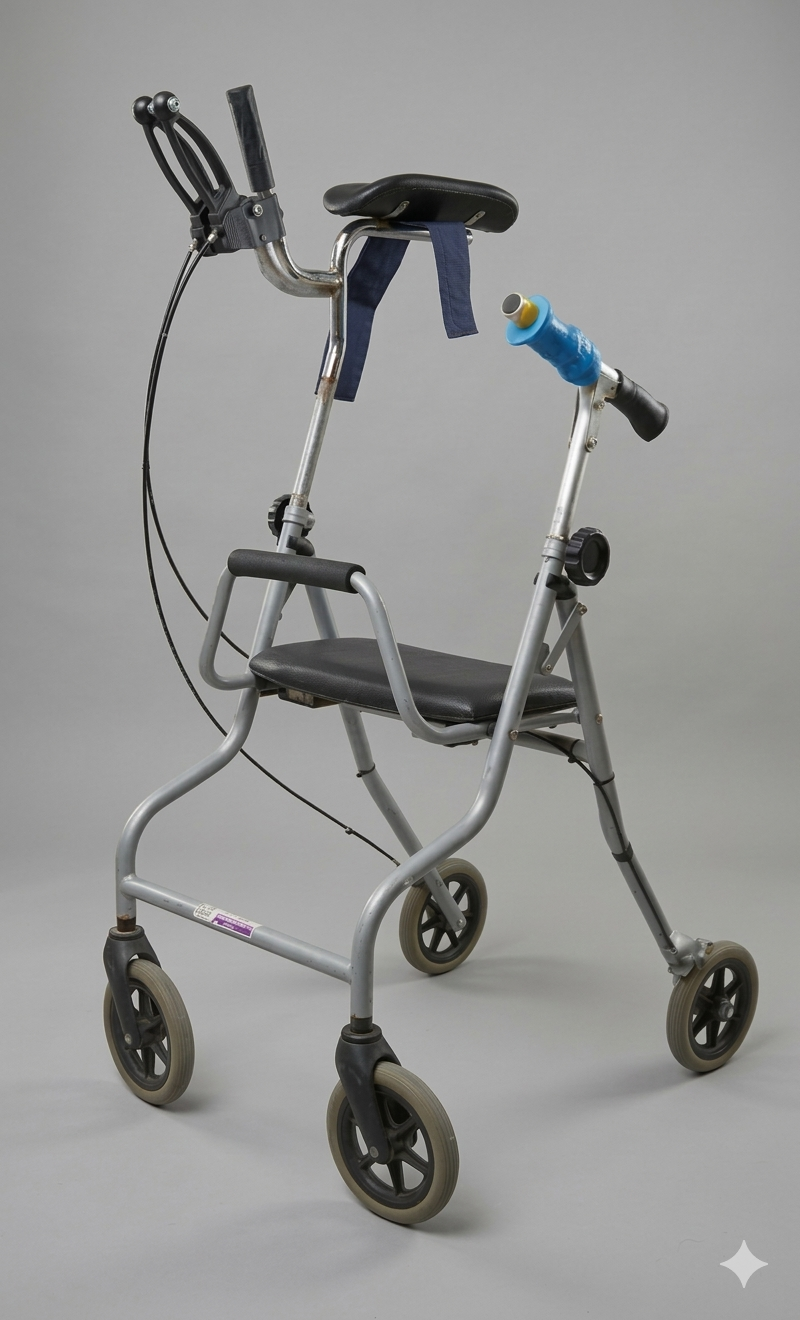
The Hybrid Walker was developed to assist users like Aviad, who require targeted support for one the left side during gait training. By providing a stabilized frame, the walker reduces the physical strain on caregivers and durable enough for outdoor use.
Who it helps
Designed for individuals requiring asymmetrical mobility support. This device is ideal for users who need significant stability on one side of the body without sacrificing overall range of motion or independence.
How it works
This design solves asymmetrical mobility by providing targeted support to the weaker side without restricting the stronger side. All-terrain wheels enable outdoor use, fostering user independence and reducing physical strain on caregivers.
Our Hybrid Walker blends a standard grip with a contoured forearm support, providing targeted stability for a weaker side without restricting mobility. Integrated all-terrain wheels ensure smooth, confident navigation for both indoor and outdoor use.
Tools needed
PC or MAC I7 +
Fusion 360
Prusa slicer
Measurement tool
Digital caliber
Screwdriver set
Pliers
sewing machine
Electric Srewdriver
FDM Printer
Project details
- Stage: Working Model
- Built by the TOM International Community community, Global
- Team: Aviad
- Category: Daily Living, Therapy, Outdoor
- 3 downloads
The build files for Hybrid Walker are free to download from this page - open source, shared by TOM: Tikkun Olam Makers.
Related projects
- PVC Pipe walker for children with balance difficulties
- PVC Walker
- Cup Holder for walker
- Exo-Walk - Assistive Walker
- Walker Storage
- Zuhria Team -Hasoub Abilities Program-
Browse all TOM projects · Search projects · TOM communities · Makeathons and events