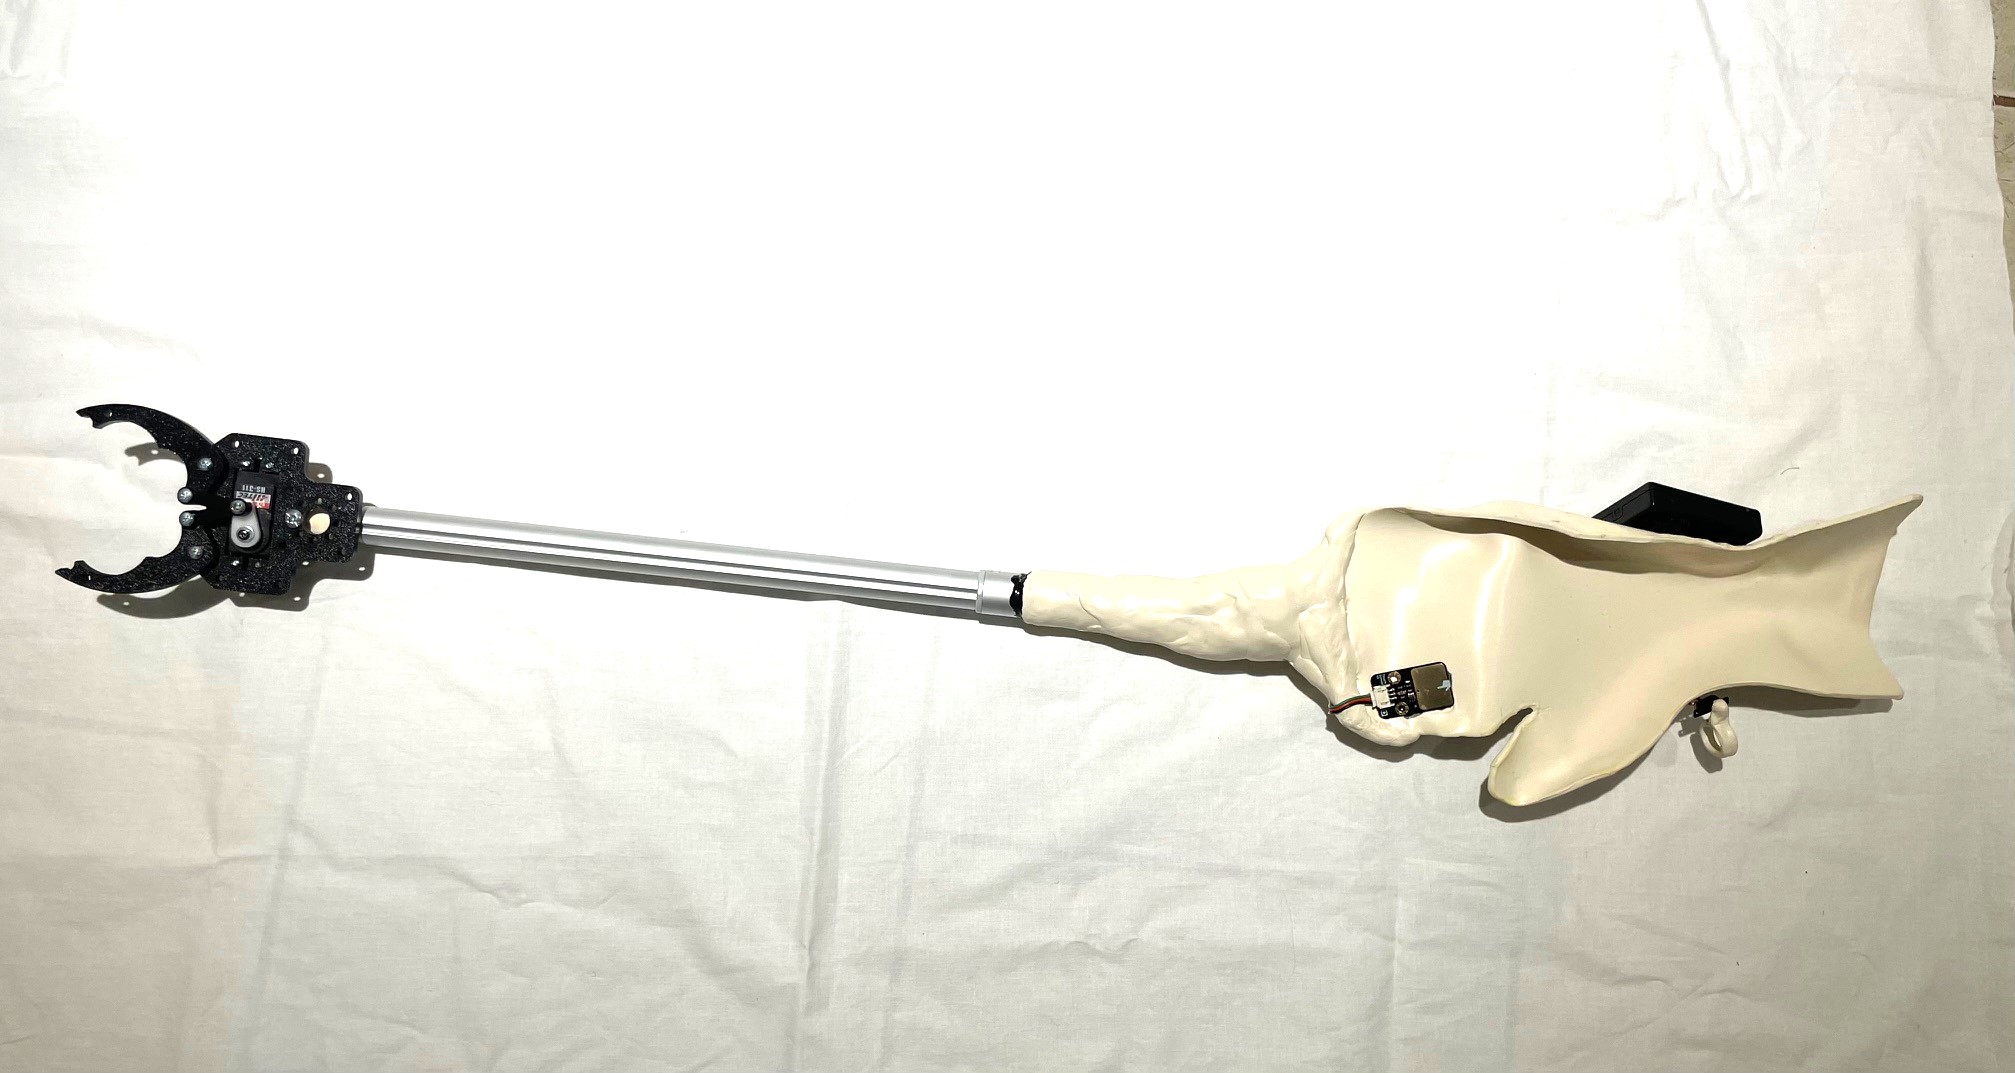
Telescoping Low-Grip Robotic Reacher
The challenge
Our Need Knower would like to independently retrieve dropped items from the floor without having to rely on the utilization of her feet or waiting for her son to assist in order to retrieve items that have fallen on the floor.
Who it helps
Our Need Knower is a female diagnosed with muscular dystrophy who uses a wheelchair to navigate her environment. Her wrist drop and minimal grip strength make it nearly impossible for her to utilize a standard reacher.
How it works
This solution will allow our Need Knower to retrieve objects more independently without needing grip strength that she does not have and without relying on others or using unsafe maladaptive techniques.
We are offering a battery-operated, touch sensored, retractable robotic reacher with a mechanical claw and forearm splint that secures to facilitate remaining in place.
Tools needed
Heavy duty gloves
PC or MAC I7 +
Clamps
Pliers
Needle-nose pliers
Cutter
scissors
scissors
scissors
scissors
Electric Srewdriver
Hot air blower
Hot glue gun
FDM Printer
Stand
Soldering set
Cable stripper
Project details
- Stage: Prototype
- Built by the Widener University community, Chester, United States of America
- Team: Victoria Nedza
- Category: Daily Living
- 10 downloads
The build files for Telescoping Low-Grip Robotic Reacher are free to download from this page - open source, shared by TOM: Tikkun Olam Makers.
Related projects
- Modular Grip Device
- Retractable Low-Dexterity Dog Clasp
- MeasureUp Utensil Grip
- Silicone grip for a standard maison jar
- Painting Tool Grip
- Low strength buttom
Browse all TOM projects · Search projects · TOM communities · Makeathons and events